
Tuesday, August 25, 2015
Inspiring imagery
Timmy and the Finnish divers, Emmi and Kari, have been gathering data via diving today. We look forward "seeing" this tomorrow via the AUV and ROV!


First day in Malta
We've had a very productive first day orienting to Malta and meeting with our international collaborators.


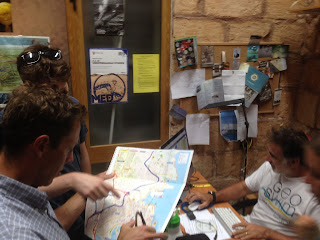


Seeing some of the data that the Finnish divers, Immi Wallin and Kari Hyttinen, have acquired in the IT faculty building at the University of Malta (thanks Matthew!)

Immi, Api, Chris, Matthew Montebello,Timmy, Kari, Katie and Ian

On the campus of the University of Malta discussing marine archeology with Immi (specifically methods for removing silt from ship wrecks for mapping)

Timmy showing us an amphora removed from a Phoenician wreck (http://www.sci-news.com/archaeology/science-phoenician-shipwreck-malta-02118.html)

Planning in Timmy's office.
And the AUV finally cleared customs so Chris and Api could replace the batteries and get it ready for missions tomorrow.


Meanwhile, Katie and Ian worked testing Agisoft to reconstruct a 3D scene from still images using photogrammetry.

Travels to Malta
We've made it to Malta! It was a long 24 hours of travel but we didn't run into any major problems. I had a scare at the SFO airport when my terminal was closed due to a security threat and I heard all flights were grounded. I was sent to another terminal with a huge security line, but I made it through the line in time and my flight left only half an hour late.
I met Zoë and Ian at LAX and we got the four suitcases containing the ROV and tools checked for the flight. We had a long flight to Zurich and made it to Malta right as the sun was setting.
 |
| View of San Francisco Bay from my flight |
 |
| My first view of Malta! |
We were relieved to see someone at the airport waiting with our names on signs. After we made it to our apartment, the three of us went on a walk to the harbor. We came back to our apartment to find Chris and Api and all headed to bed exhausted.
Sunday, August 23, 2015

Hi! I'm Katie, a Computer Science major at Cal Poly about to start my fifth year. Unlike everyone else, I haven't been involved with ICEX before, so I don't really know what I'm getting myself into. But I'm excited to find out! I'll be working on data visualization and generally making myself useful.
Zoë originally approached my about this project a year and a half ago and I can't believe it's actually happening. I've been reading the blog from ICEX 2013 to try and prepare myself. I've never been to Europe so I'm stoked to see Malta and get involved with this research. My bags are packed and I leave for the airport in an hour. See you soon Malta!
Hello!

I'll also be taking an annoying number of photos and videos of the deployments. Assuming a reliable internet connection, I'll be posting a lot of those here!
If I have to be honest, my ulterior motive is to go to St. George's cave, tie a rock to the ROV, see what's at the bottom. The depths are calling.
Saturday, August 22, 2015

As Chris alluded to in his earlier post, sonar imagery works kind of like shining a flashlight in a dark room - while objects in the room do light up and become visible, they do cast shadows, which may obscure details behind them. What this means is that when collecting sonar data, you need imagery from different vantage points to get a complete picture.
I've been developing a system by which the AUV can look at the images it has collected, figure out where the unknown areas are, and compute the vantage points that will fill in these gaps. The robot can then plan its path around these vantage points to efficiently map the environment.
The majority of this work has being done in simulation so far, but I'm looking forward to testing the system in the field in Malta!
Apoorva Sharma
Harvey Mudd College
Engineering '16
Our preliminary work at Catalina Island has shown we have been able to integrate a BlueView 2D imaging sonar with our Iver2 AUV. The image below shows the AUV diving on a mission to map out a local shipwreck.

The missions have been successful, and we have been working mapping them with standard mapping algorithms and filters (e.g. Kalman Filtering). One partially constructed map is shown below. The light green line depicts the AUV trajectory. Dark blue areas are not observed due to the sonar being side mounted and limited in beam width. The wreck can be seen coming through from the bottom left scans that have been fused within elevation map. Acoustic shadows are clearly visible, indicating the need for multiple points of sensor vantage points, (and hence intelligent planning).


The missions have been successful, and we have been working mapping them with standard mapping algorithms and filters (e.g. Kalman Filtering). One partially constructed map is shown below. The light green line depicts the AUV trajectory. Dark blue areas are not observed due to the sonar being side mounted and limited in beam width. The wreck can be seen coming through from the bottom left scans that have been fused within elevation map. Acoustic shadows are clearly visible, indicating the need for multiple points of sensor vantage points, (and hence intelligent planning).

Subscribe to:
Posts (Atom)